Muhammad Zareii

Muhammad Zareii

Electronics Engineer

M.Sc. student in Wireless Communications Engineering at the University of Oulu. Previously M.Sc. Micro/Nano Electronics (Tarbiat Modares) and B.Sc. Electrical Engineering (Tabriz). Two years of industry R&D at Sepidgaman Parseh in Tehran.

About

I’ve always worked in electronics, but not in the narrow sense of just designing circuits. For me, it’s one continuous system that starts from physics and extends all the way to working machines — from the physics of devices, to circuit and hardware design, to embedded systems and higher-level algorithms.

What interests me is the connection between layers. The same electron that follows quantum mechanics in a material ends up shaping a signal on a PCB, a control loop in firmware, or data going into a model. I haven’t really switched fields over time — I’ve just worked at different levels of the same system, trying to understand how these layers fit together and influence one another.

My work reflects that. I’ve built optical and electromagnetic simulations, designed circuits and PCBs, developed embedded systems, and worked on perception and machine learning problems. Many of these ideas have been tested in real systems, from robotics platforms to sensing and communication setups, where constraints and imperfections matter as much as theory. Different tools, same mindset: understand the system from the ground up, and make sure it actually works in practice.

I care about physical correctness. Whether it’s checking energy conservation in an optical model or validating a hardware system on the bench, I don’t like treating simulations or abstractions as black boxes.

This portfolio is organized the same way I think — as a stack. From physics and simulation at the bottom, through hardware and embedded systems, up to higher-level intelligence. Each layer builds on the previous one, and understanding their interaction is a central part of how I work.
Education

M.Sc. Wireless Communications Engineering
University of Oulu, Finland · 2025–present
M.Sc. Micro/Nano Electronics
Tarbiat Modares University · coursework completed
Quantum Electronics · Optoelectronics I–II · Advanced Solid State Physics · Advanced Optics
B.Sc. Electrical Engineering
University of Tabriz

Contact

Research Interests

Two areas I am actively reading and thinking about.

D2NN & Optical Analog Computing

Diffractive Deep Neural Networks · Angular Spectrum Method · Physical AI

Diffractive Deep Neural Networks (D2NN, Lin et al. 2018) perform inference entirely in the optical domain: phase masks replace weight matrices, and computation happens at the speed of light through free-space diffraction. My interest is in the physical feasibility gap — the distance between a network that converges in simulation and one that can actually be fabricated. This involves sampling theory (ASM band-limit), energy conservation, photon-budget analysis, SNR under detector noise, and Monte Carlo fabrication tolerance analysis. More broadly, I am interested in what it means to implement neural network operations with physical substrates rather than transistors.

Angular Spectrum Method FDTD Optical Computing Physical AI Wave Optics

QISAT — Quantum Integrated Sensing & Communication

CV-QKD · Distributed Optical Fiber Sensing · ISAQN

The Xu et al. 2024 ISAQN framework (Integrated Sensing And Quantum communication Networks) demonstrates that quantum key distribution (CV-QKD) and distributed optical fiber sensing (DOFS) can coexist on the same fiber through frequency-division multiplexing. The sensing channel uses Rayleigh backscattering for vibration sensing, with pilot-tone phase recovery bringing it to the quantum noise limit — meaning the sensing precision is bounded by quantum mechanics, not classical electronics. I am interested in this convergence: using the same infrastructure for both secure communication and physical-world sensing, and the signal processing that makes both work simultaneously without mutual degradation.

CV-QKD DOFS Quantum Sensing Photonics Signal Processing

Projects by Layer

Sixteen projects across four levels of the electronics stack.

Layer 1

Physical & Simulation

Device-level physics, electromagnetic simulation, quantum mechanics, photonic design — the foundation.

D2NN
Physical

D2NN Physical Feasibility Evaluator

ASM propagation engine with five quantitative checks: band-limit, energy conservation, photon budget, SNR, and Monte Carlo fabrication tolerance.

SWG-MMI Mode Demultiplexer
Physical

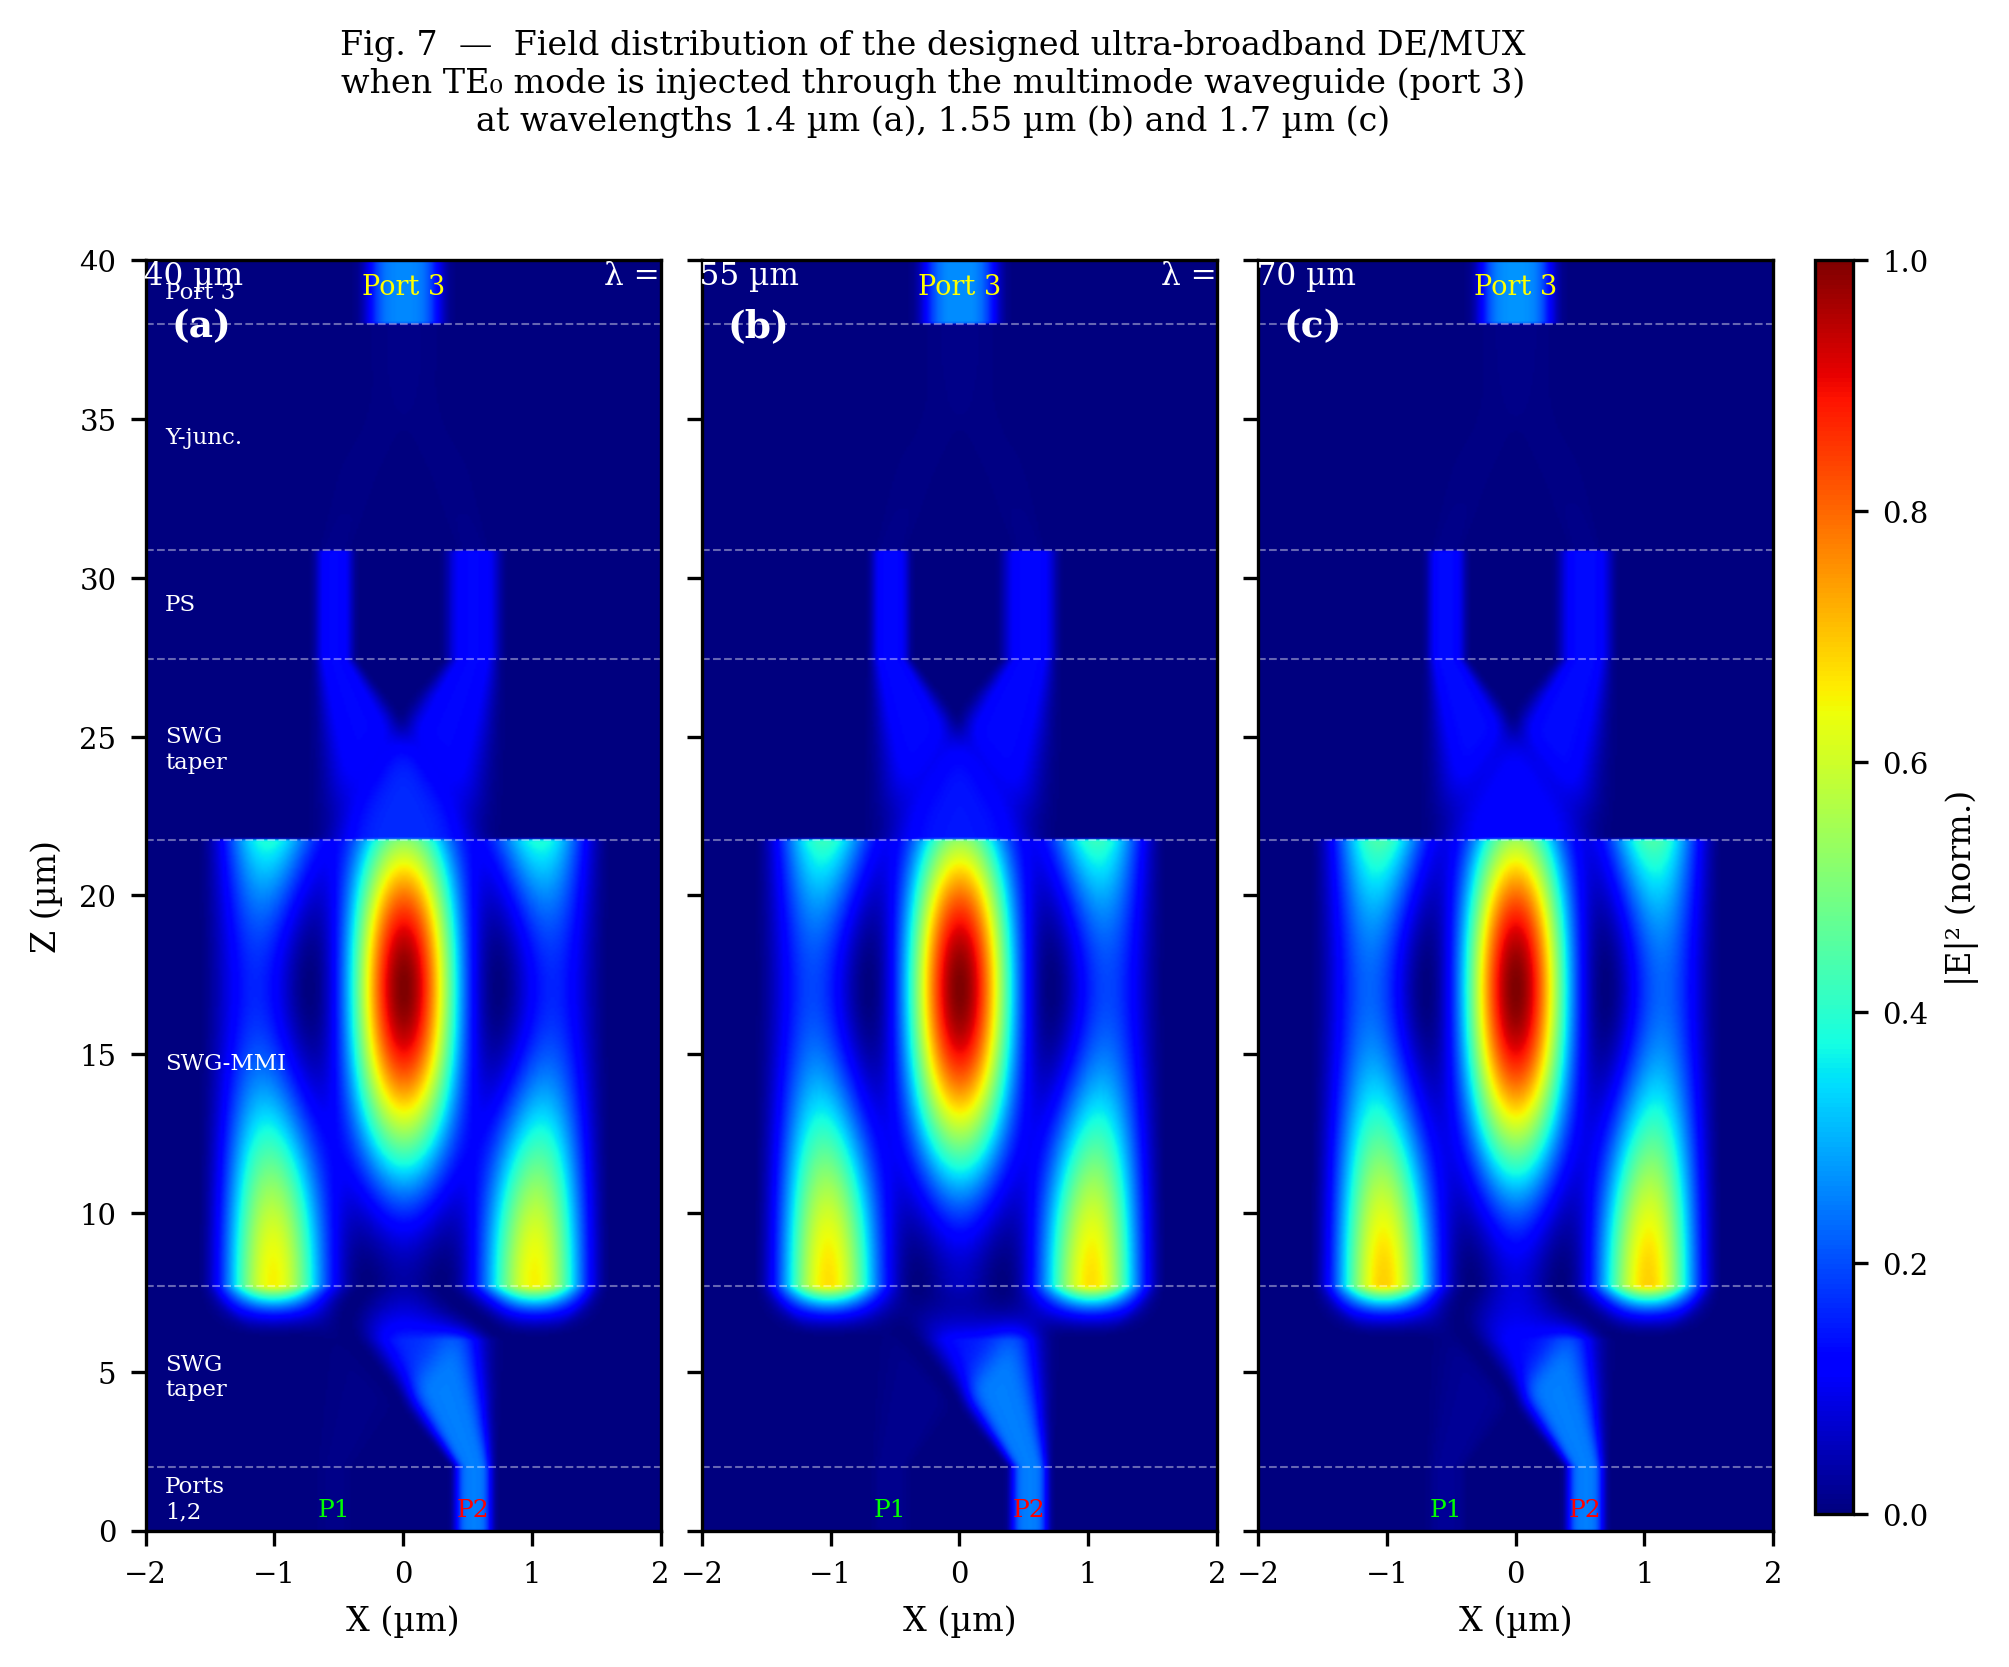
SWG-MMI Mode Demultiplexer

Analytical SOI mode demultiplexer — EMT, EIM, MMI self-imaging, full 2D field reconstruction across 300 nm bandwidth. Validated against Lumerical FDTD; scripts available upon request.

BIC Sensor
Physical

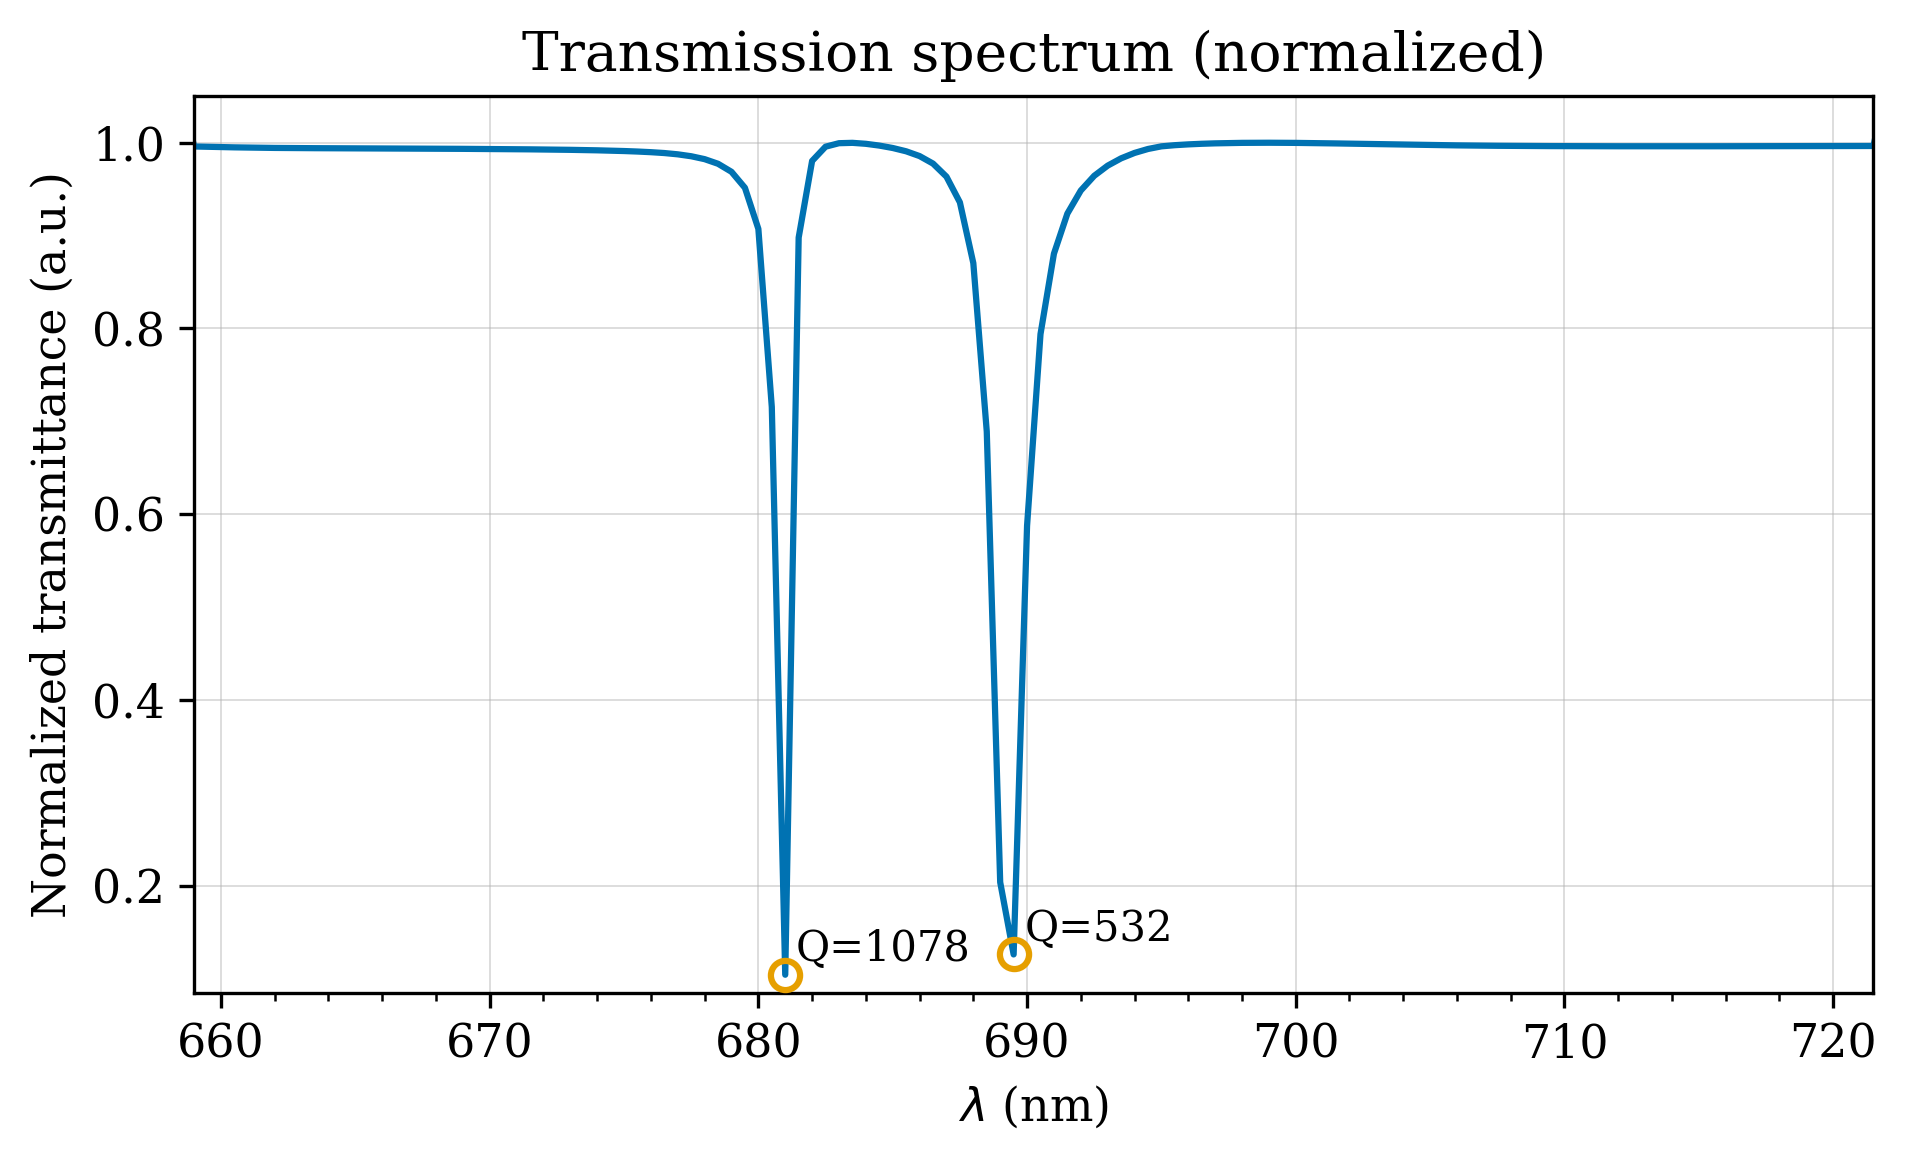
BIC Photonic Cell Sensor

Bound-state-in-the-continuum Si nanocube resonator (Q > 1000) for label-free cancer vs. non-cancer cell detection. COMSOL FDTD + Kramers–Kronig conversion + SVM classification.

Plasmonics
Physical

FDTD Active Plasmonics

Semiclassical Maxwell-Bloch FDTD for gain-modulated MSM waveguides and microcavities. Gold modelled with Lorentz-Drude; ~60% resonance amplitude increase demonstrated.

Slavcheva
Physical

Slavcheva Maxwell-Bloch FDTD

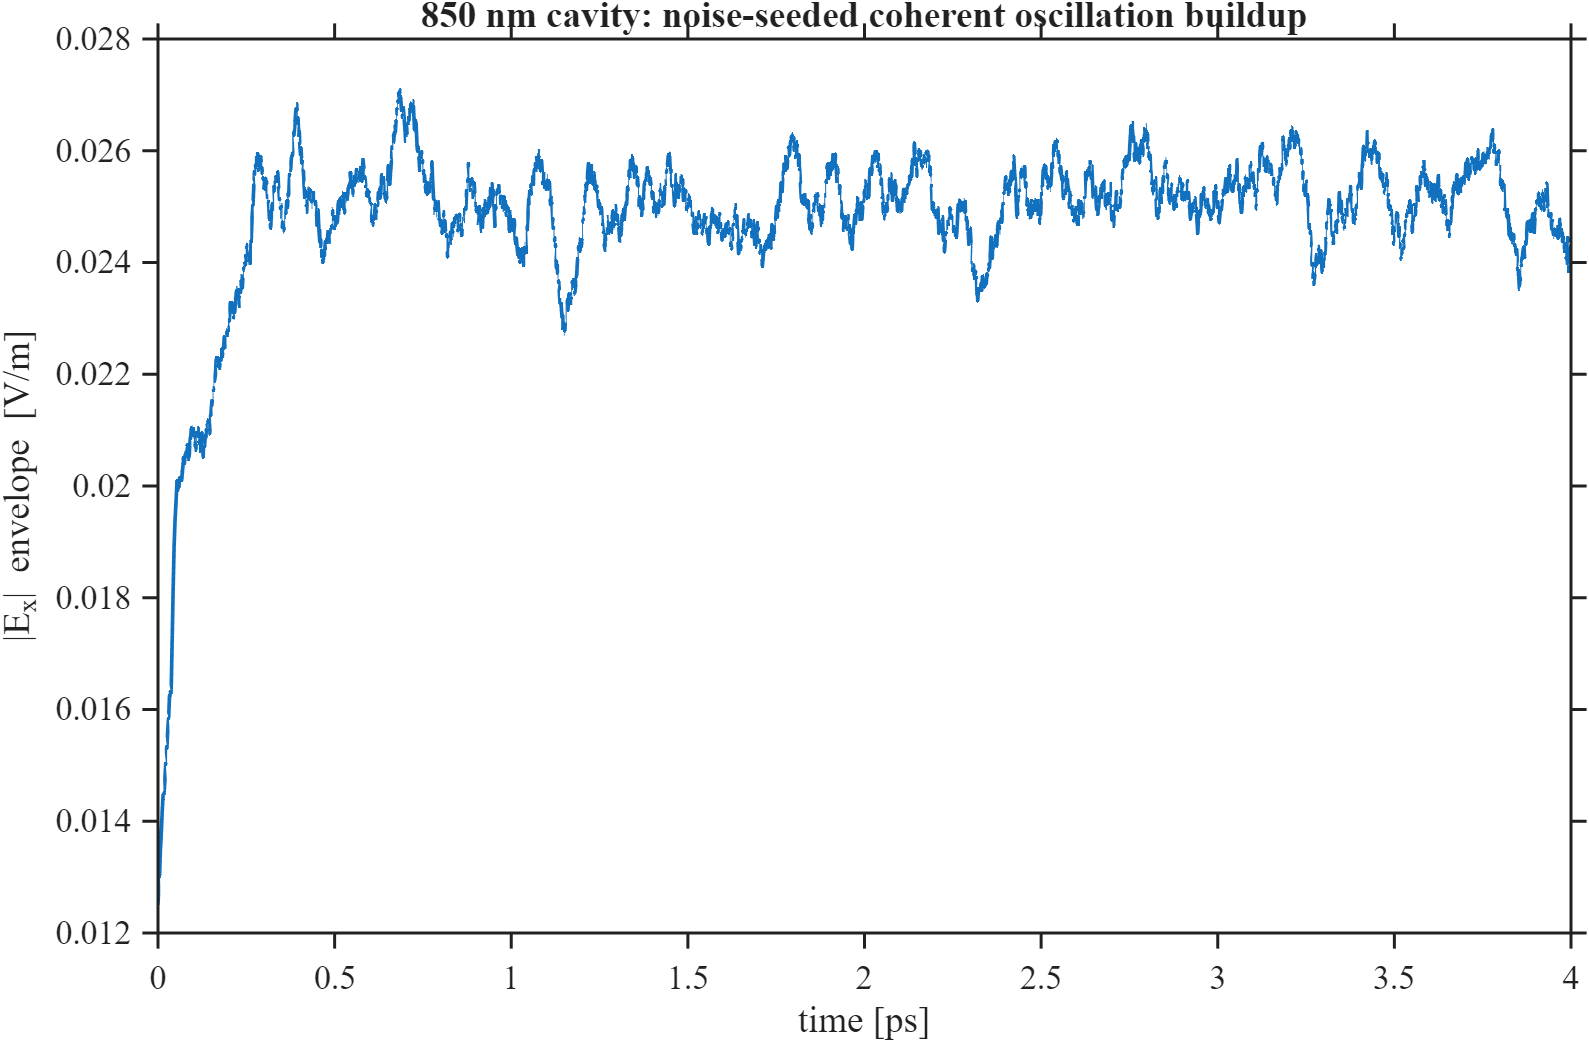
Faithful reproduction of Slavcheva et al. semiclassical FDTD for VCSEL lasing at 850 nm and 1.29 μm. 1D Yee grid, Mur ABC, gain saturation.

PhC Gates
Physical

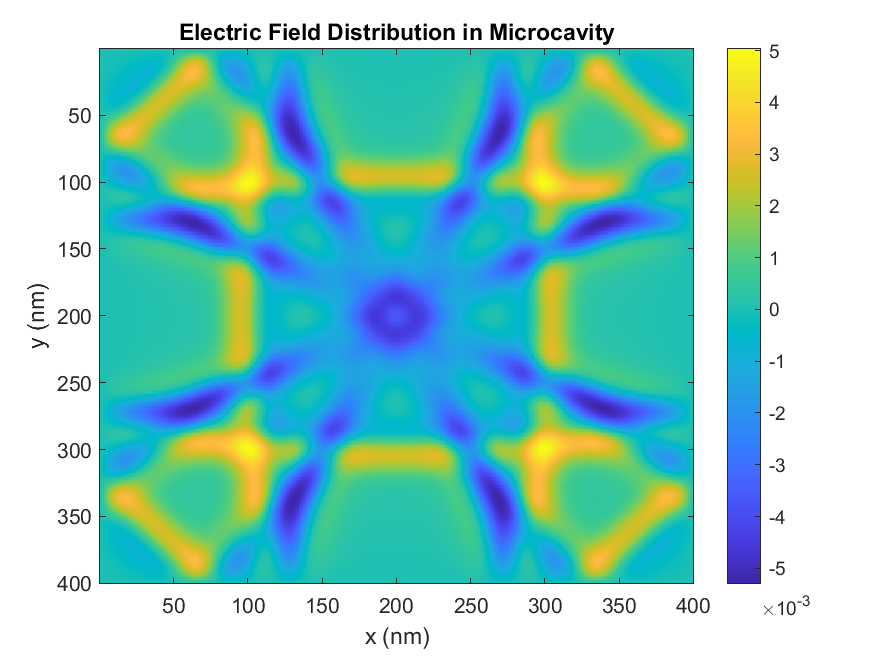
Photonic Crystal All-Optical Logic Gates

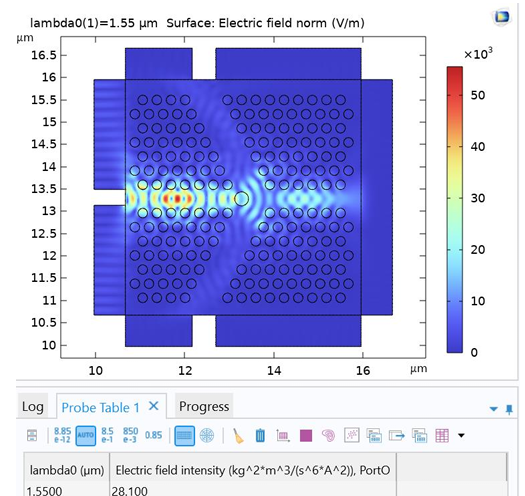
COMSOL Multiphysics 2D PhC simulation of all-optical NOT, AND, OR gates at λ = 1.55 μm based on Rani et al. 2015. Interference-based switching without nonlinearity.

Coupled QW
Physical

Coupled Quantum Well Valence Band

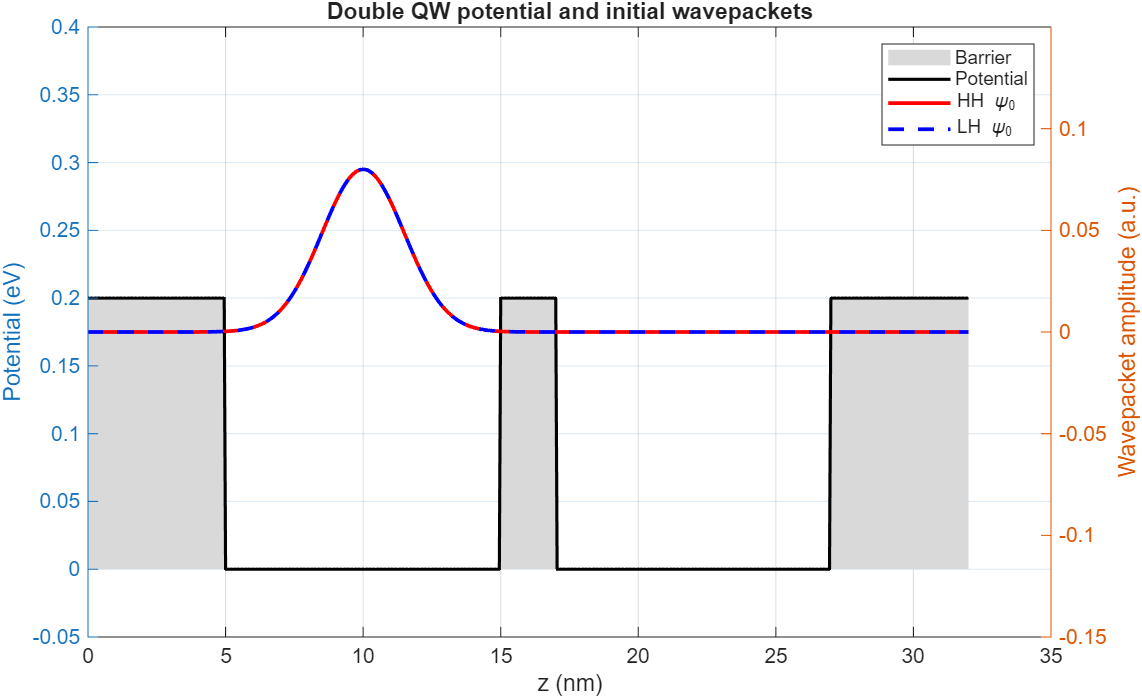
Luttinger-Kohn Hamiltonian solver for GaAs/Al₀.₅Ga₀.₅As double quantum well (25 Å / 15 Å barrier). HH/LH Gaussian wavepacket dynamics in MATLAB.

Layer 2

Circuit & Hardware

Analog and mixed-signal design, PCB, RF/inductive systems — turning physics into hardware.

FabLab
Circuit

Magnetic Wireless Multi-User Communication

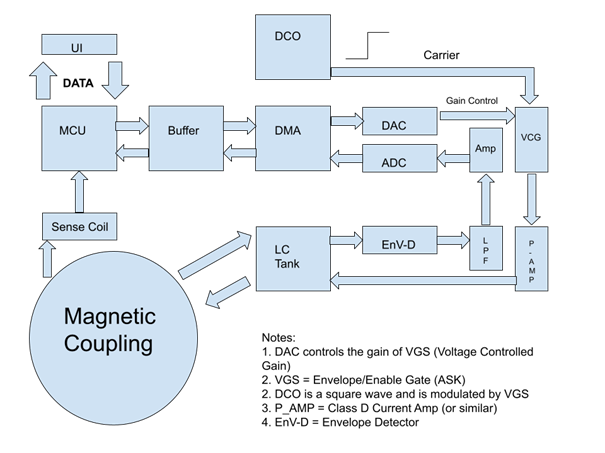
~1 MHz magnetically-coupled near-field link, push-pull LC driver, ASK/OOK modulation, beaconed TDMA MAC for up to 8 nodes over 1–3 m. University of Oulu FabLab.

Impedance
Circuit

AVR Impedance Meter

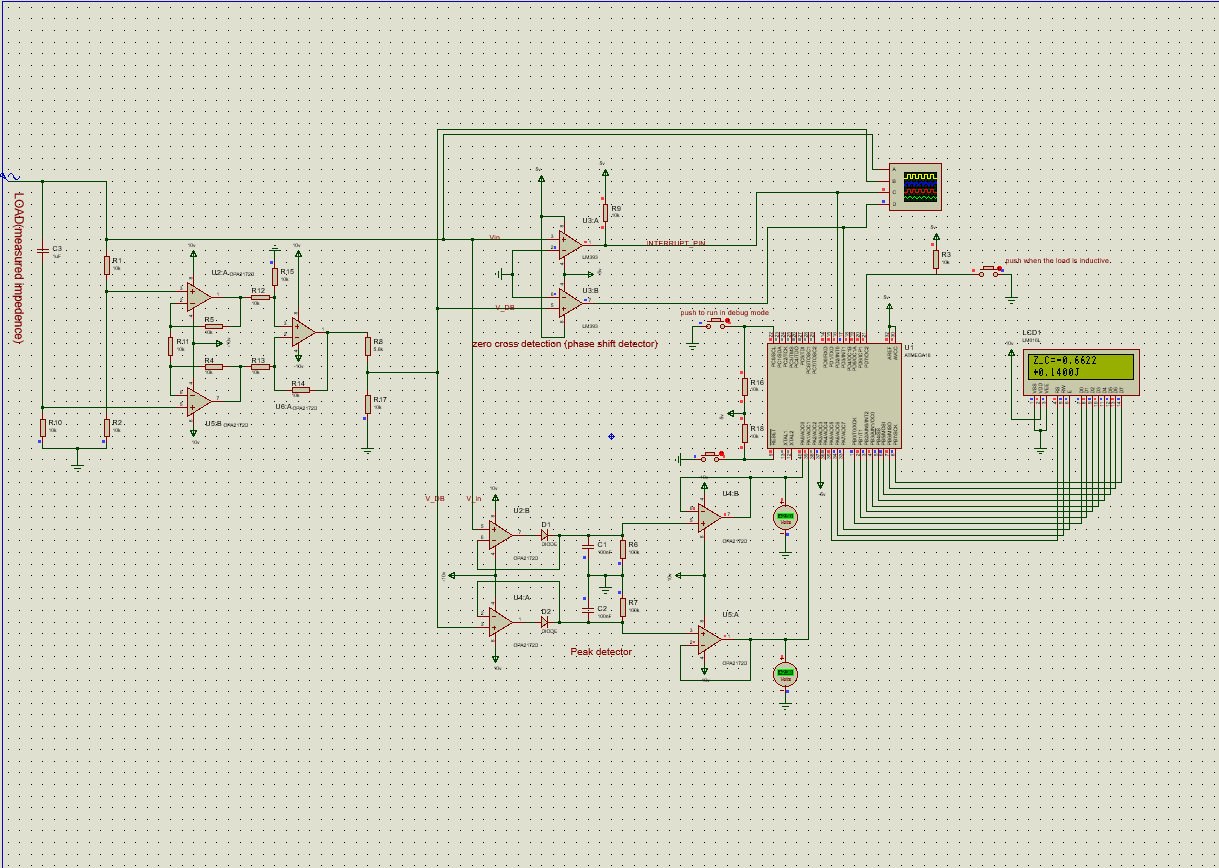
ATmega16-based impedance meter using AC bridge at 10 kHz. Peak detector and zero-crossing detector measure magnitude and phase; polar-to-rectangular conversion in firmware.

SMPS
Circuit

Switched-Mode Power Supply Design

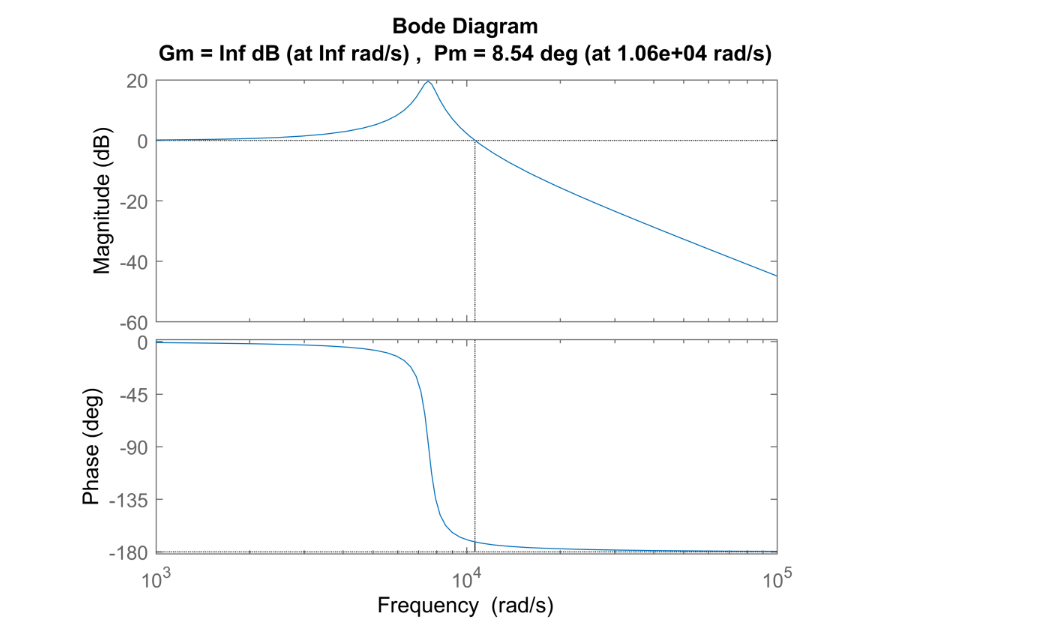
Full SMPS design cycle: topology selection, magnetics, control loop compensation (Bode analysis), PCB layout, and bench validation. Final-year undergraduate project.

Layer 3

Embedded & Firmware

RTOS design, microcontroller firmware, communication protocols, edge computing.

STM32
Embedded

STM32H743 FreeRTOS Datalogger

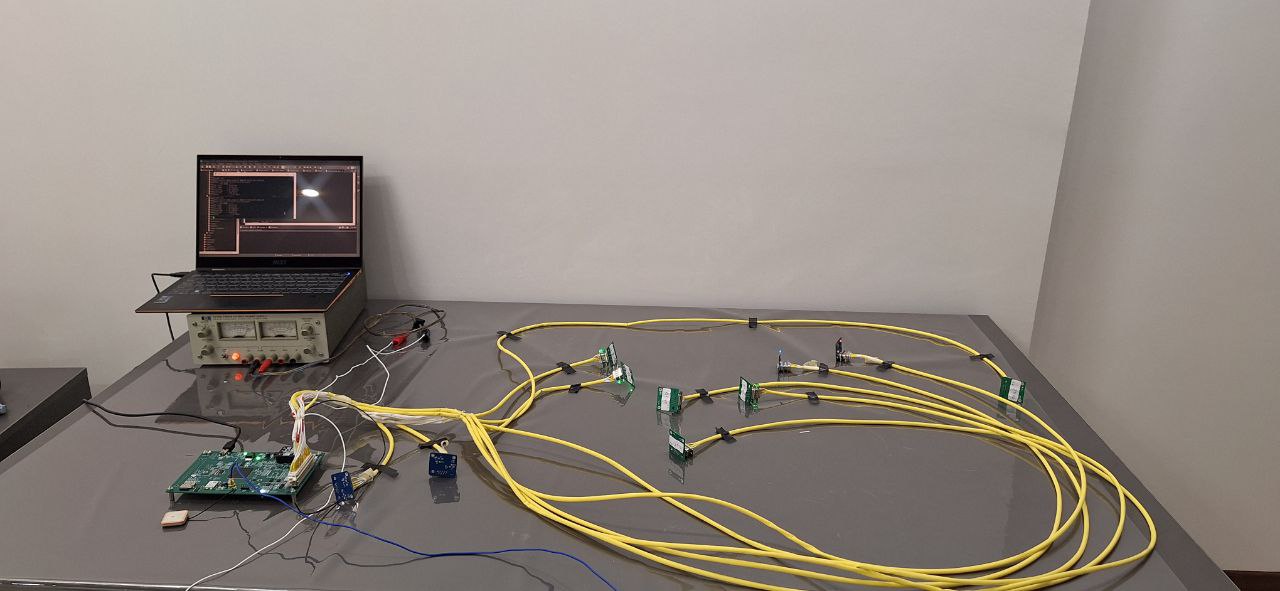
Contract-grade 6-task RTOS datalogger. 100 Hz IMU, 5 Hz GPS, RS232 telemetry, raw SD sector writes with triple-redundant pointers. Paid client project.

Webapp
Embedded

Semiconductor Process Modeling WebApp

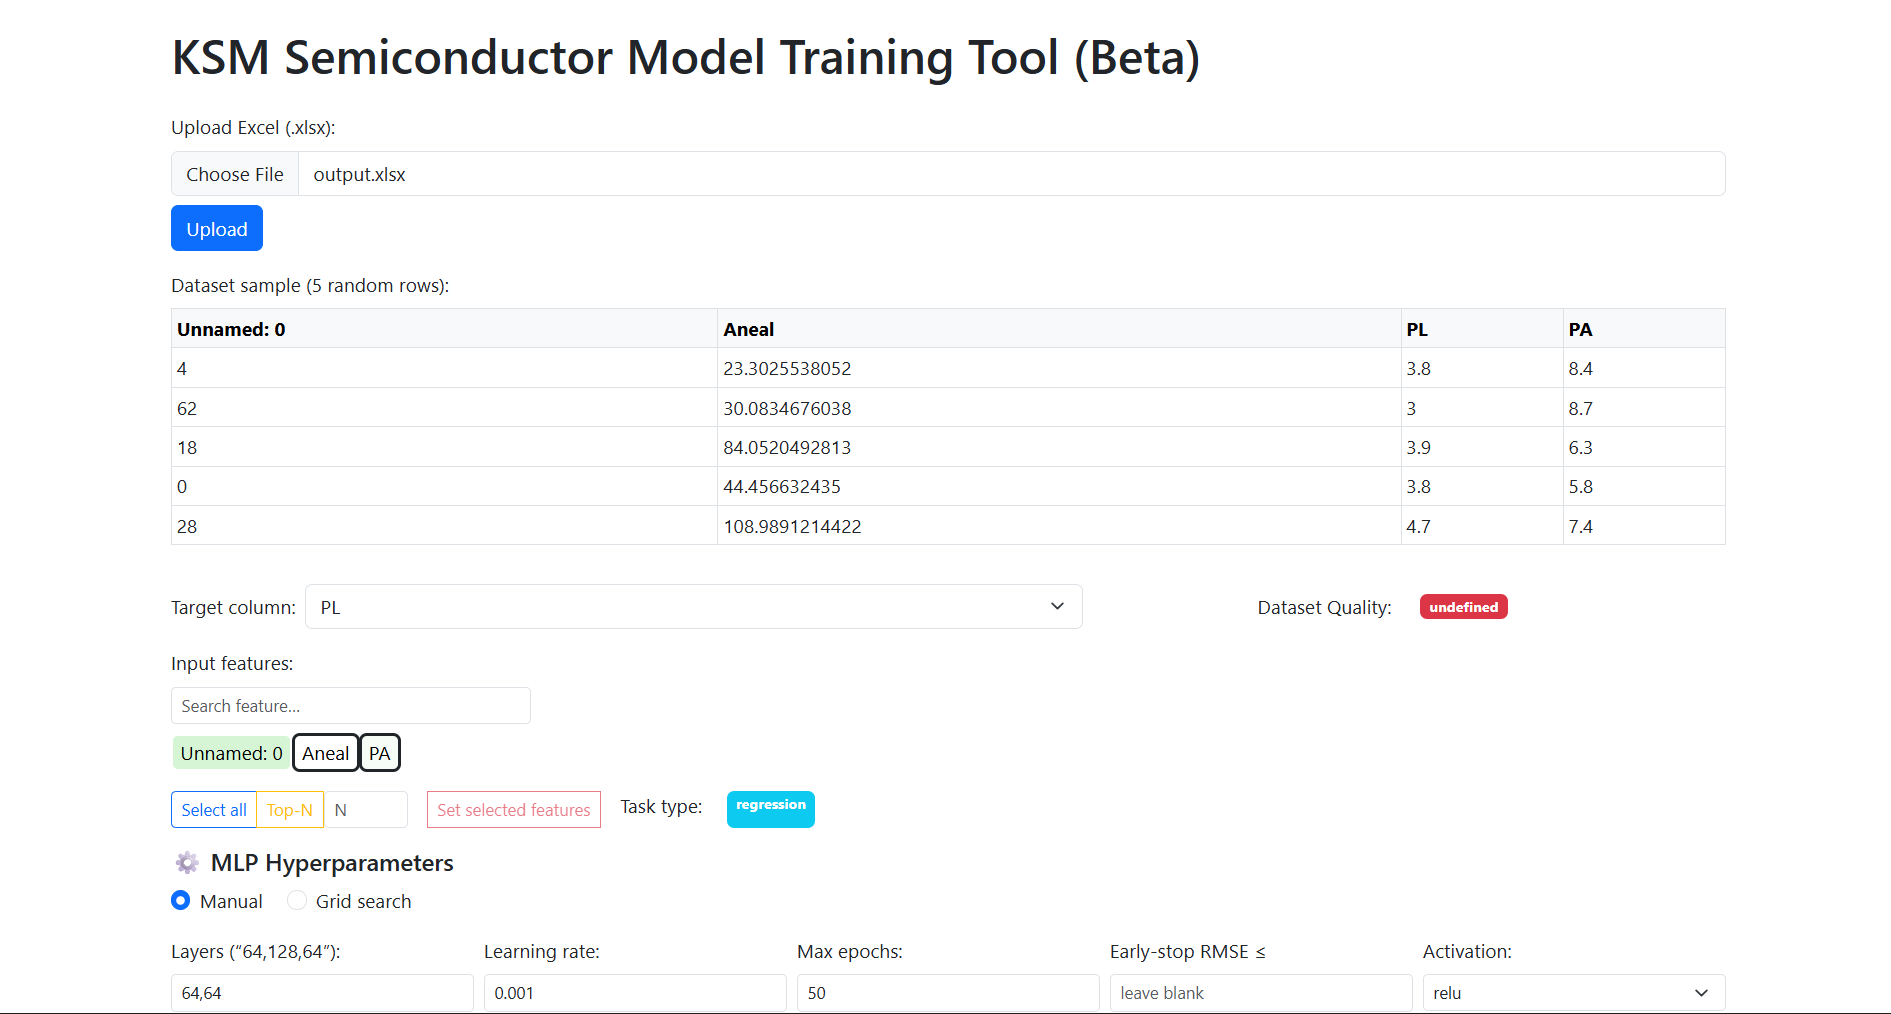
HTML/JS frontend + Python backend modeling proton-exchange and thermal-oxidation processes. Accepts Excel inputs or live sensor readings; outputs process curves in real time.

Wireless Identity
Embedded

Wireless Identity Recognition System

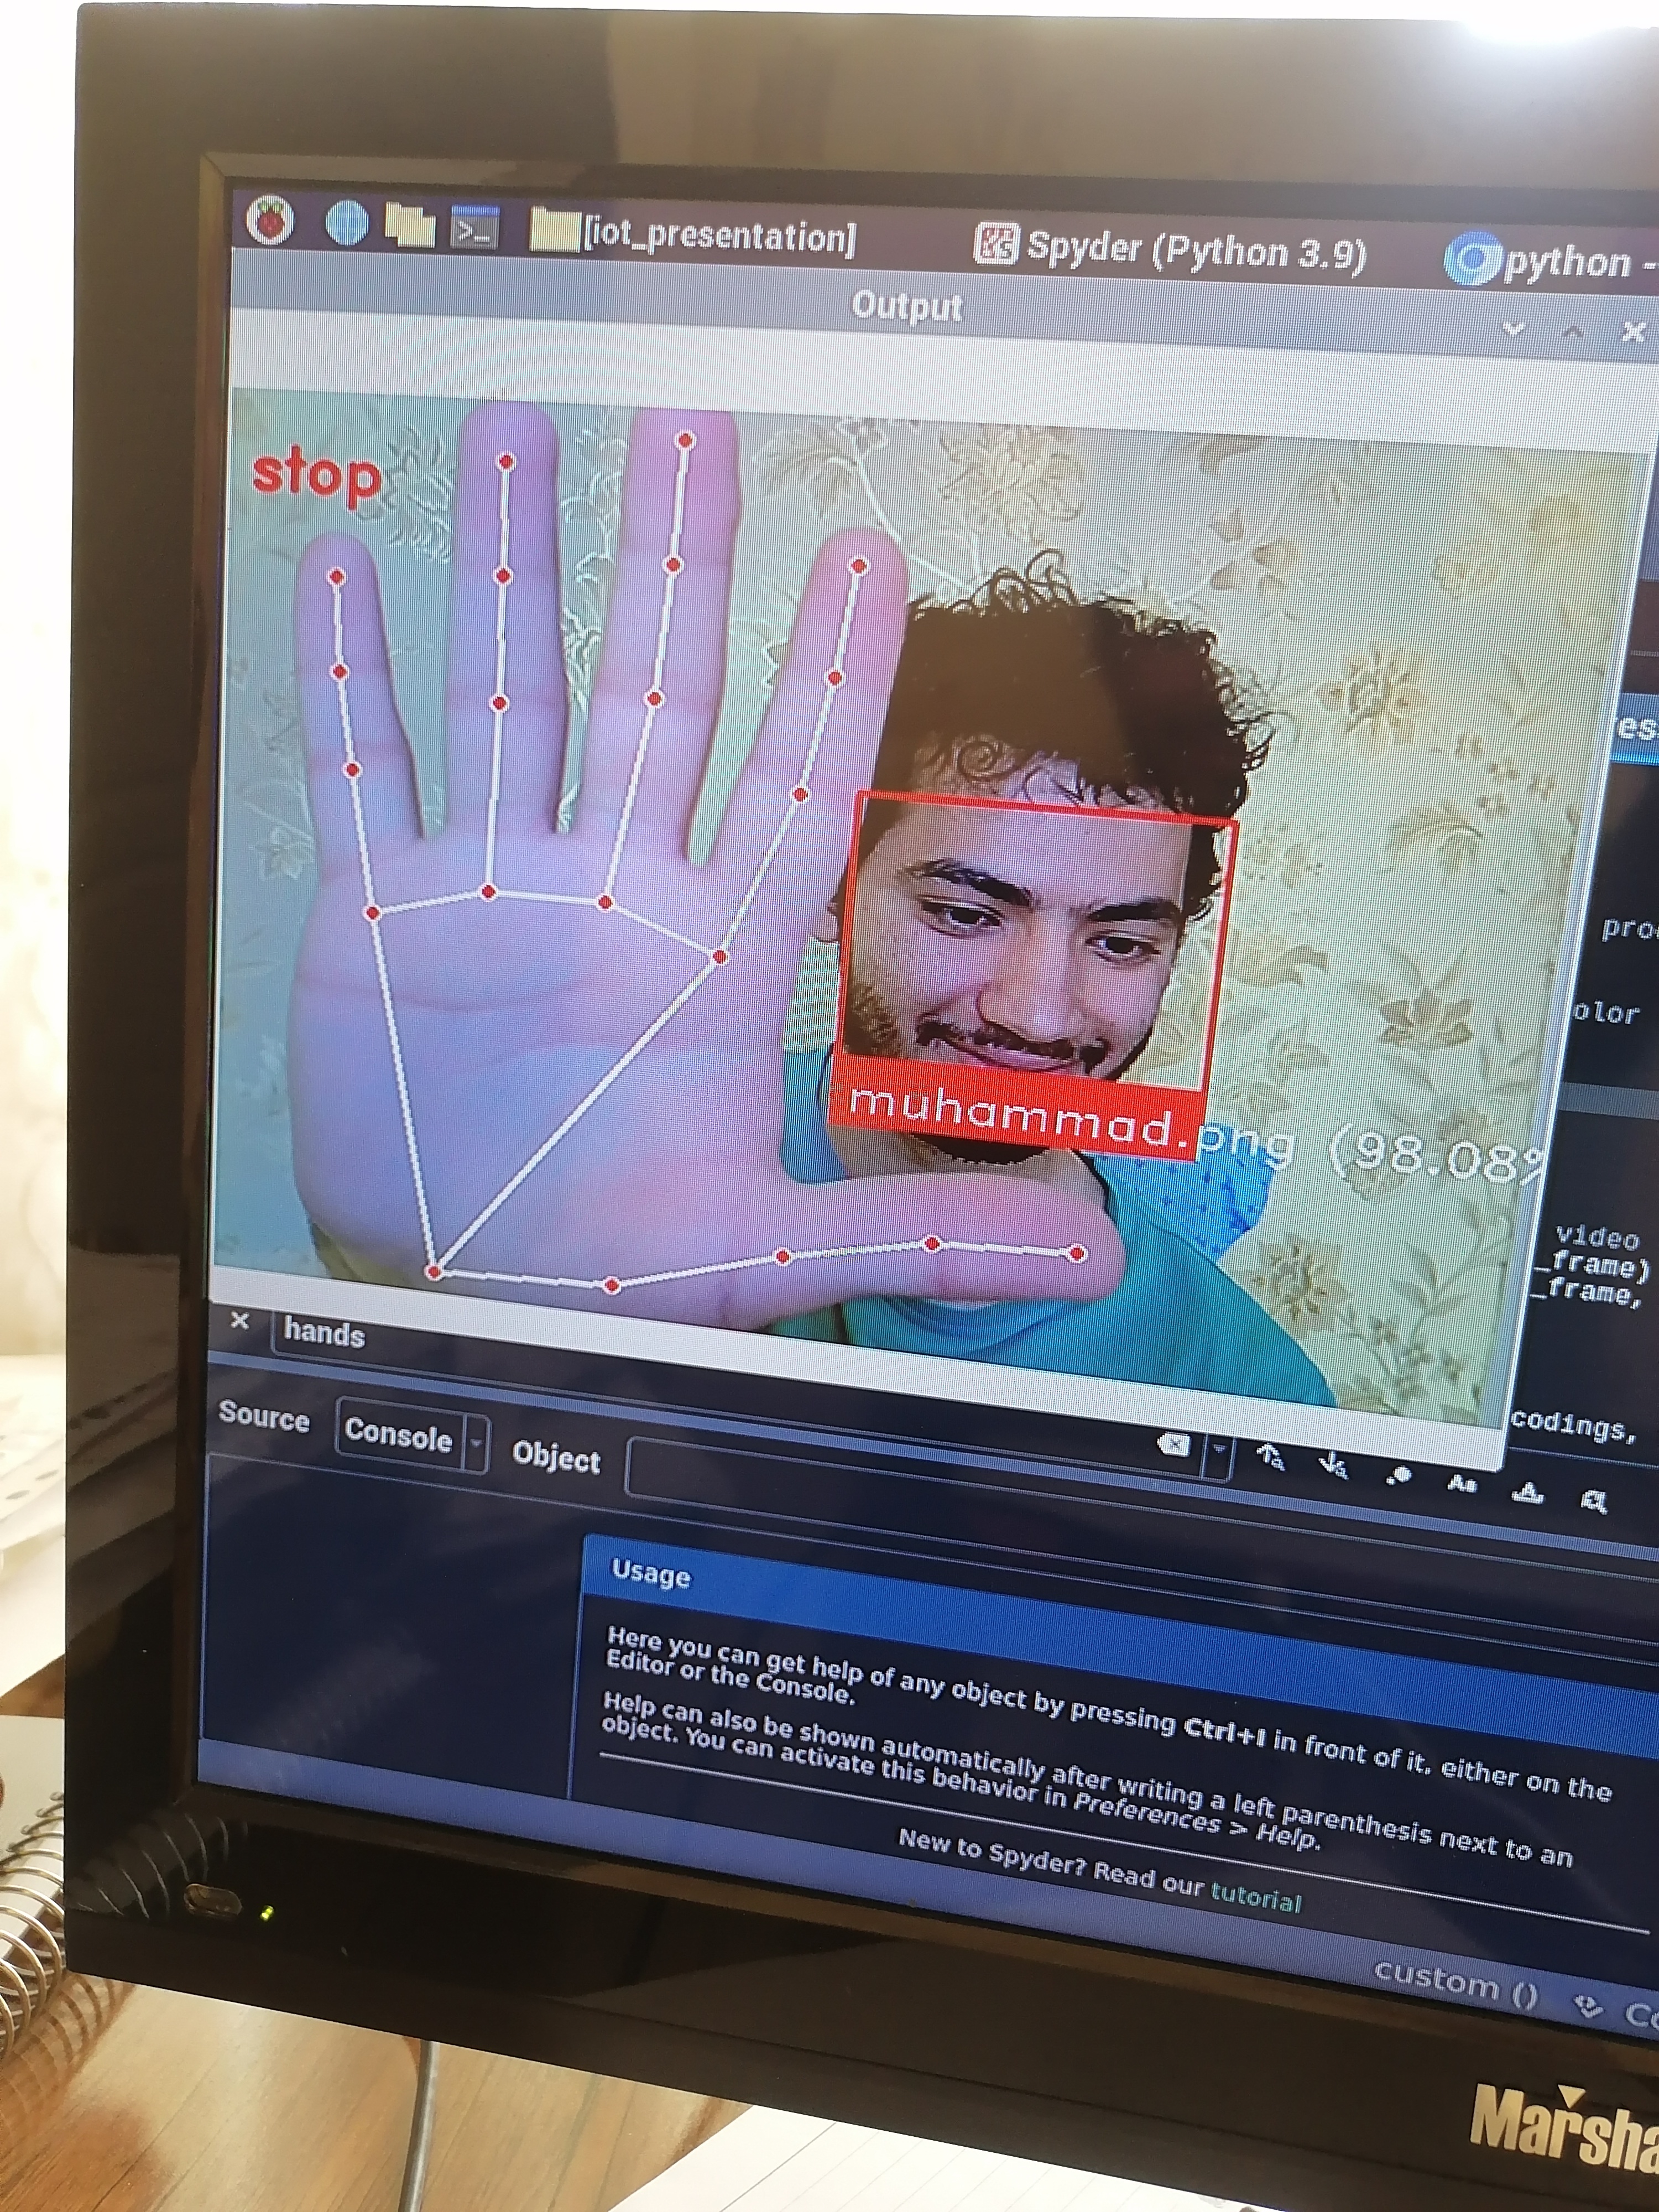
Face recognition + 9-class MediaPipe gesture recognition, dual-threaded Python client, TCP to ESP32 server. Real-time identity and gesture dispatch over Wi-Fi.

Layer 4

Applied Intelligence & Robotics

Perception, machine learning, autonomous systems — intelligence built on all lower layers.

BCI
Intelligence

Motor Imagery BCI Classification

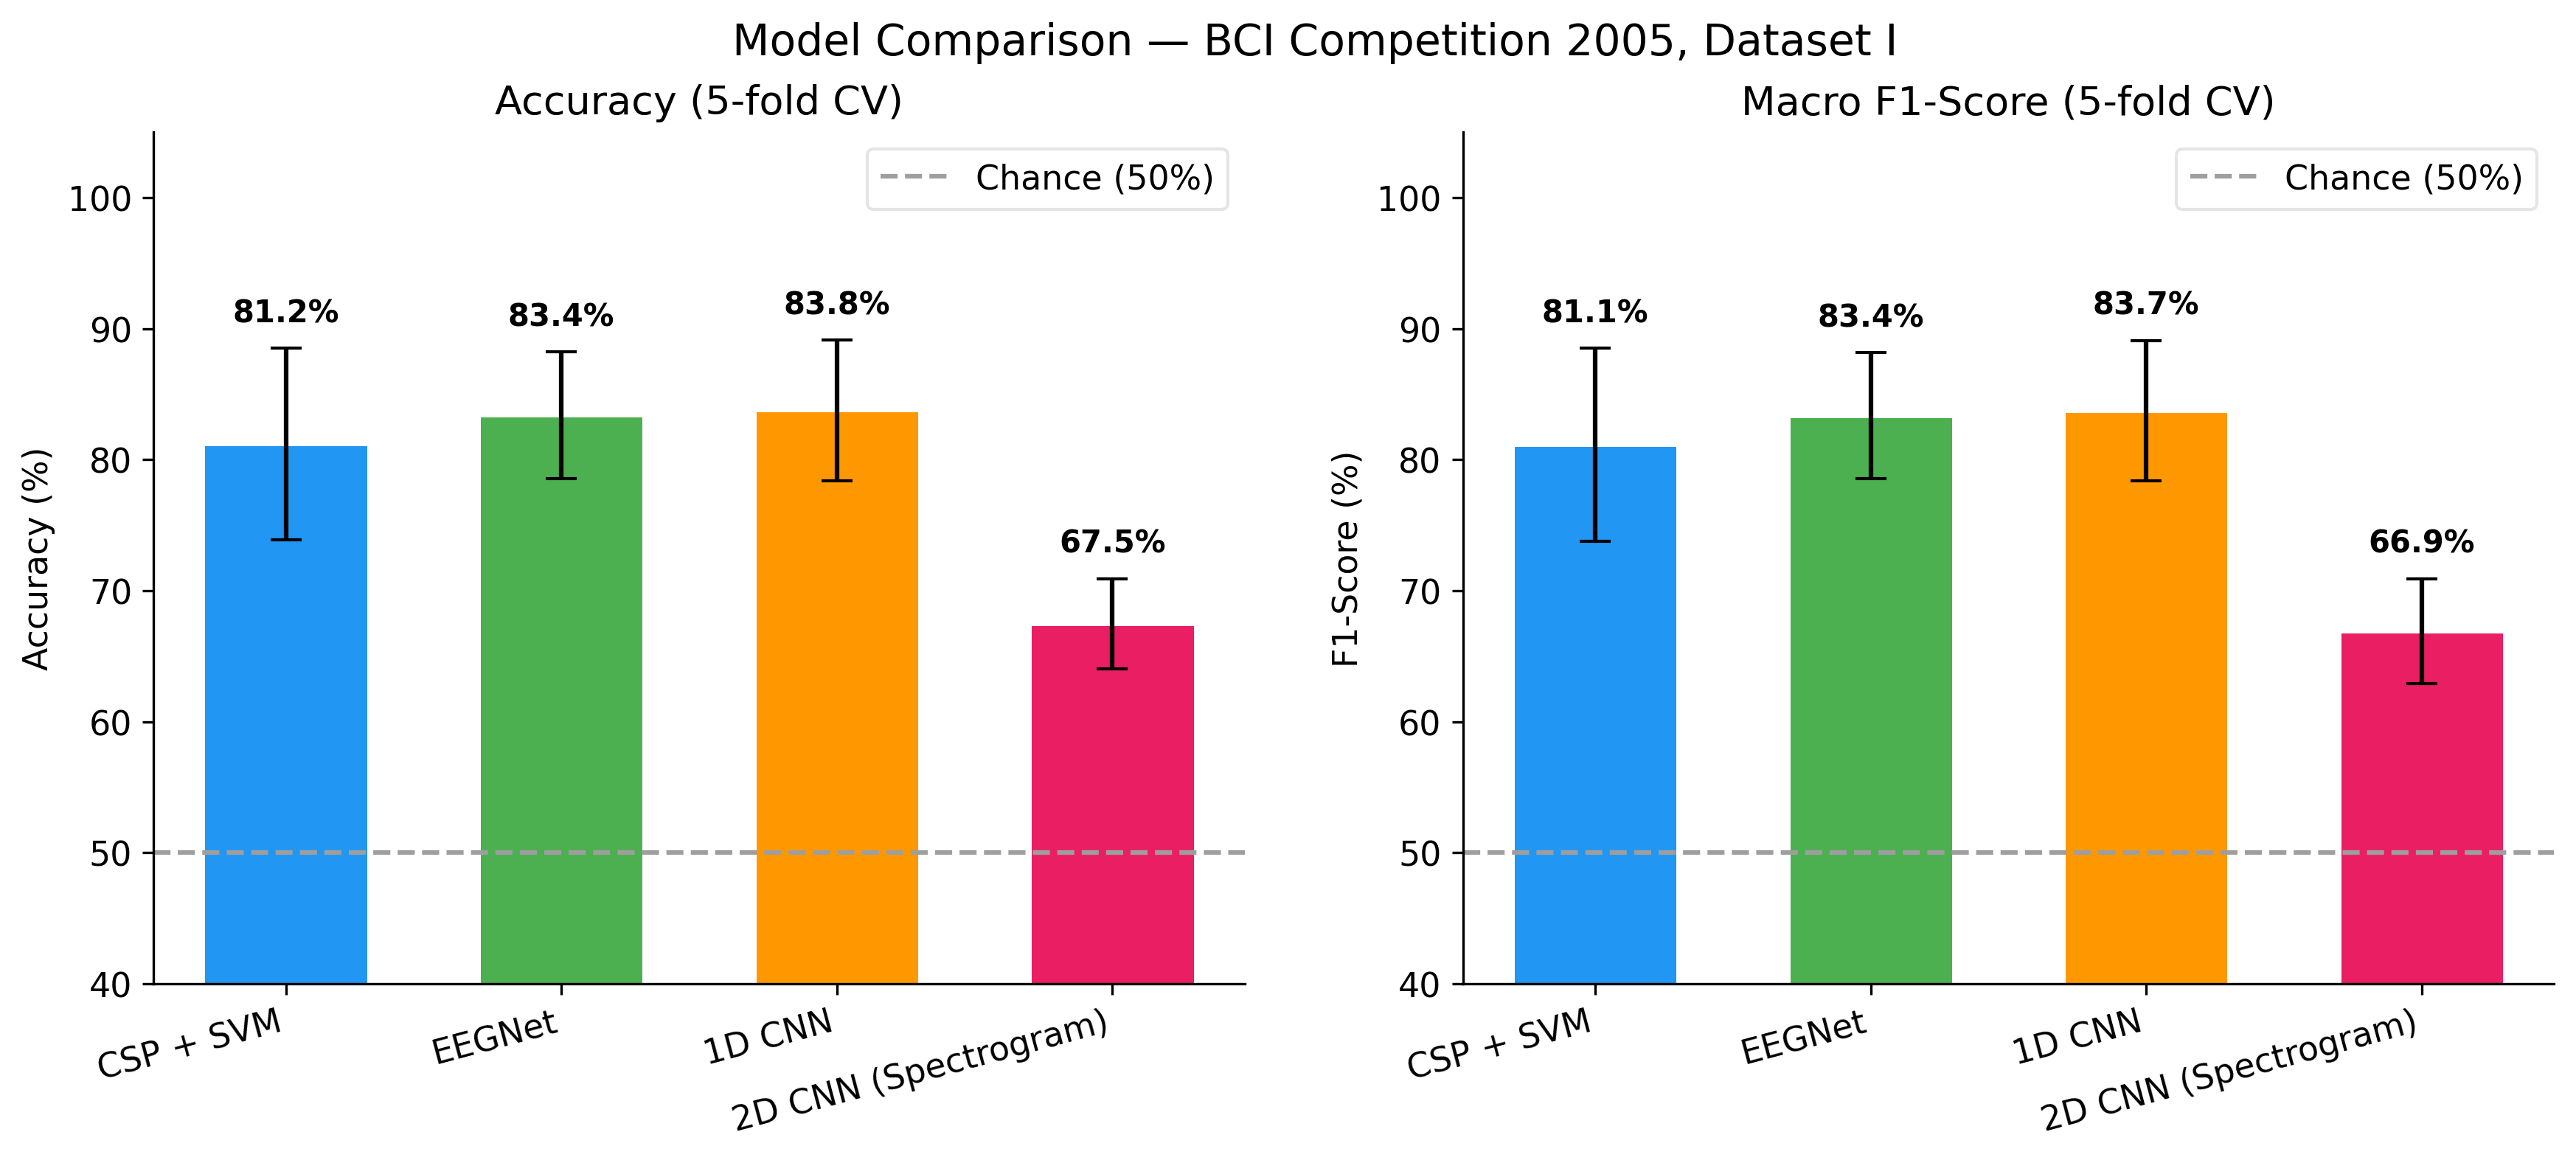
64-ch EEG at 250 Hz. Three classifiers: 1D CNN (83.8%), EEGNet (83.4%), CSP+SVM (81.2%). BCI Competition 2005 Dataset I with 5-fold stratified cross-validation.

Respeck
Intelligence

Respeck Activity Recognition

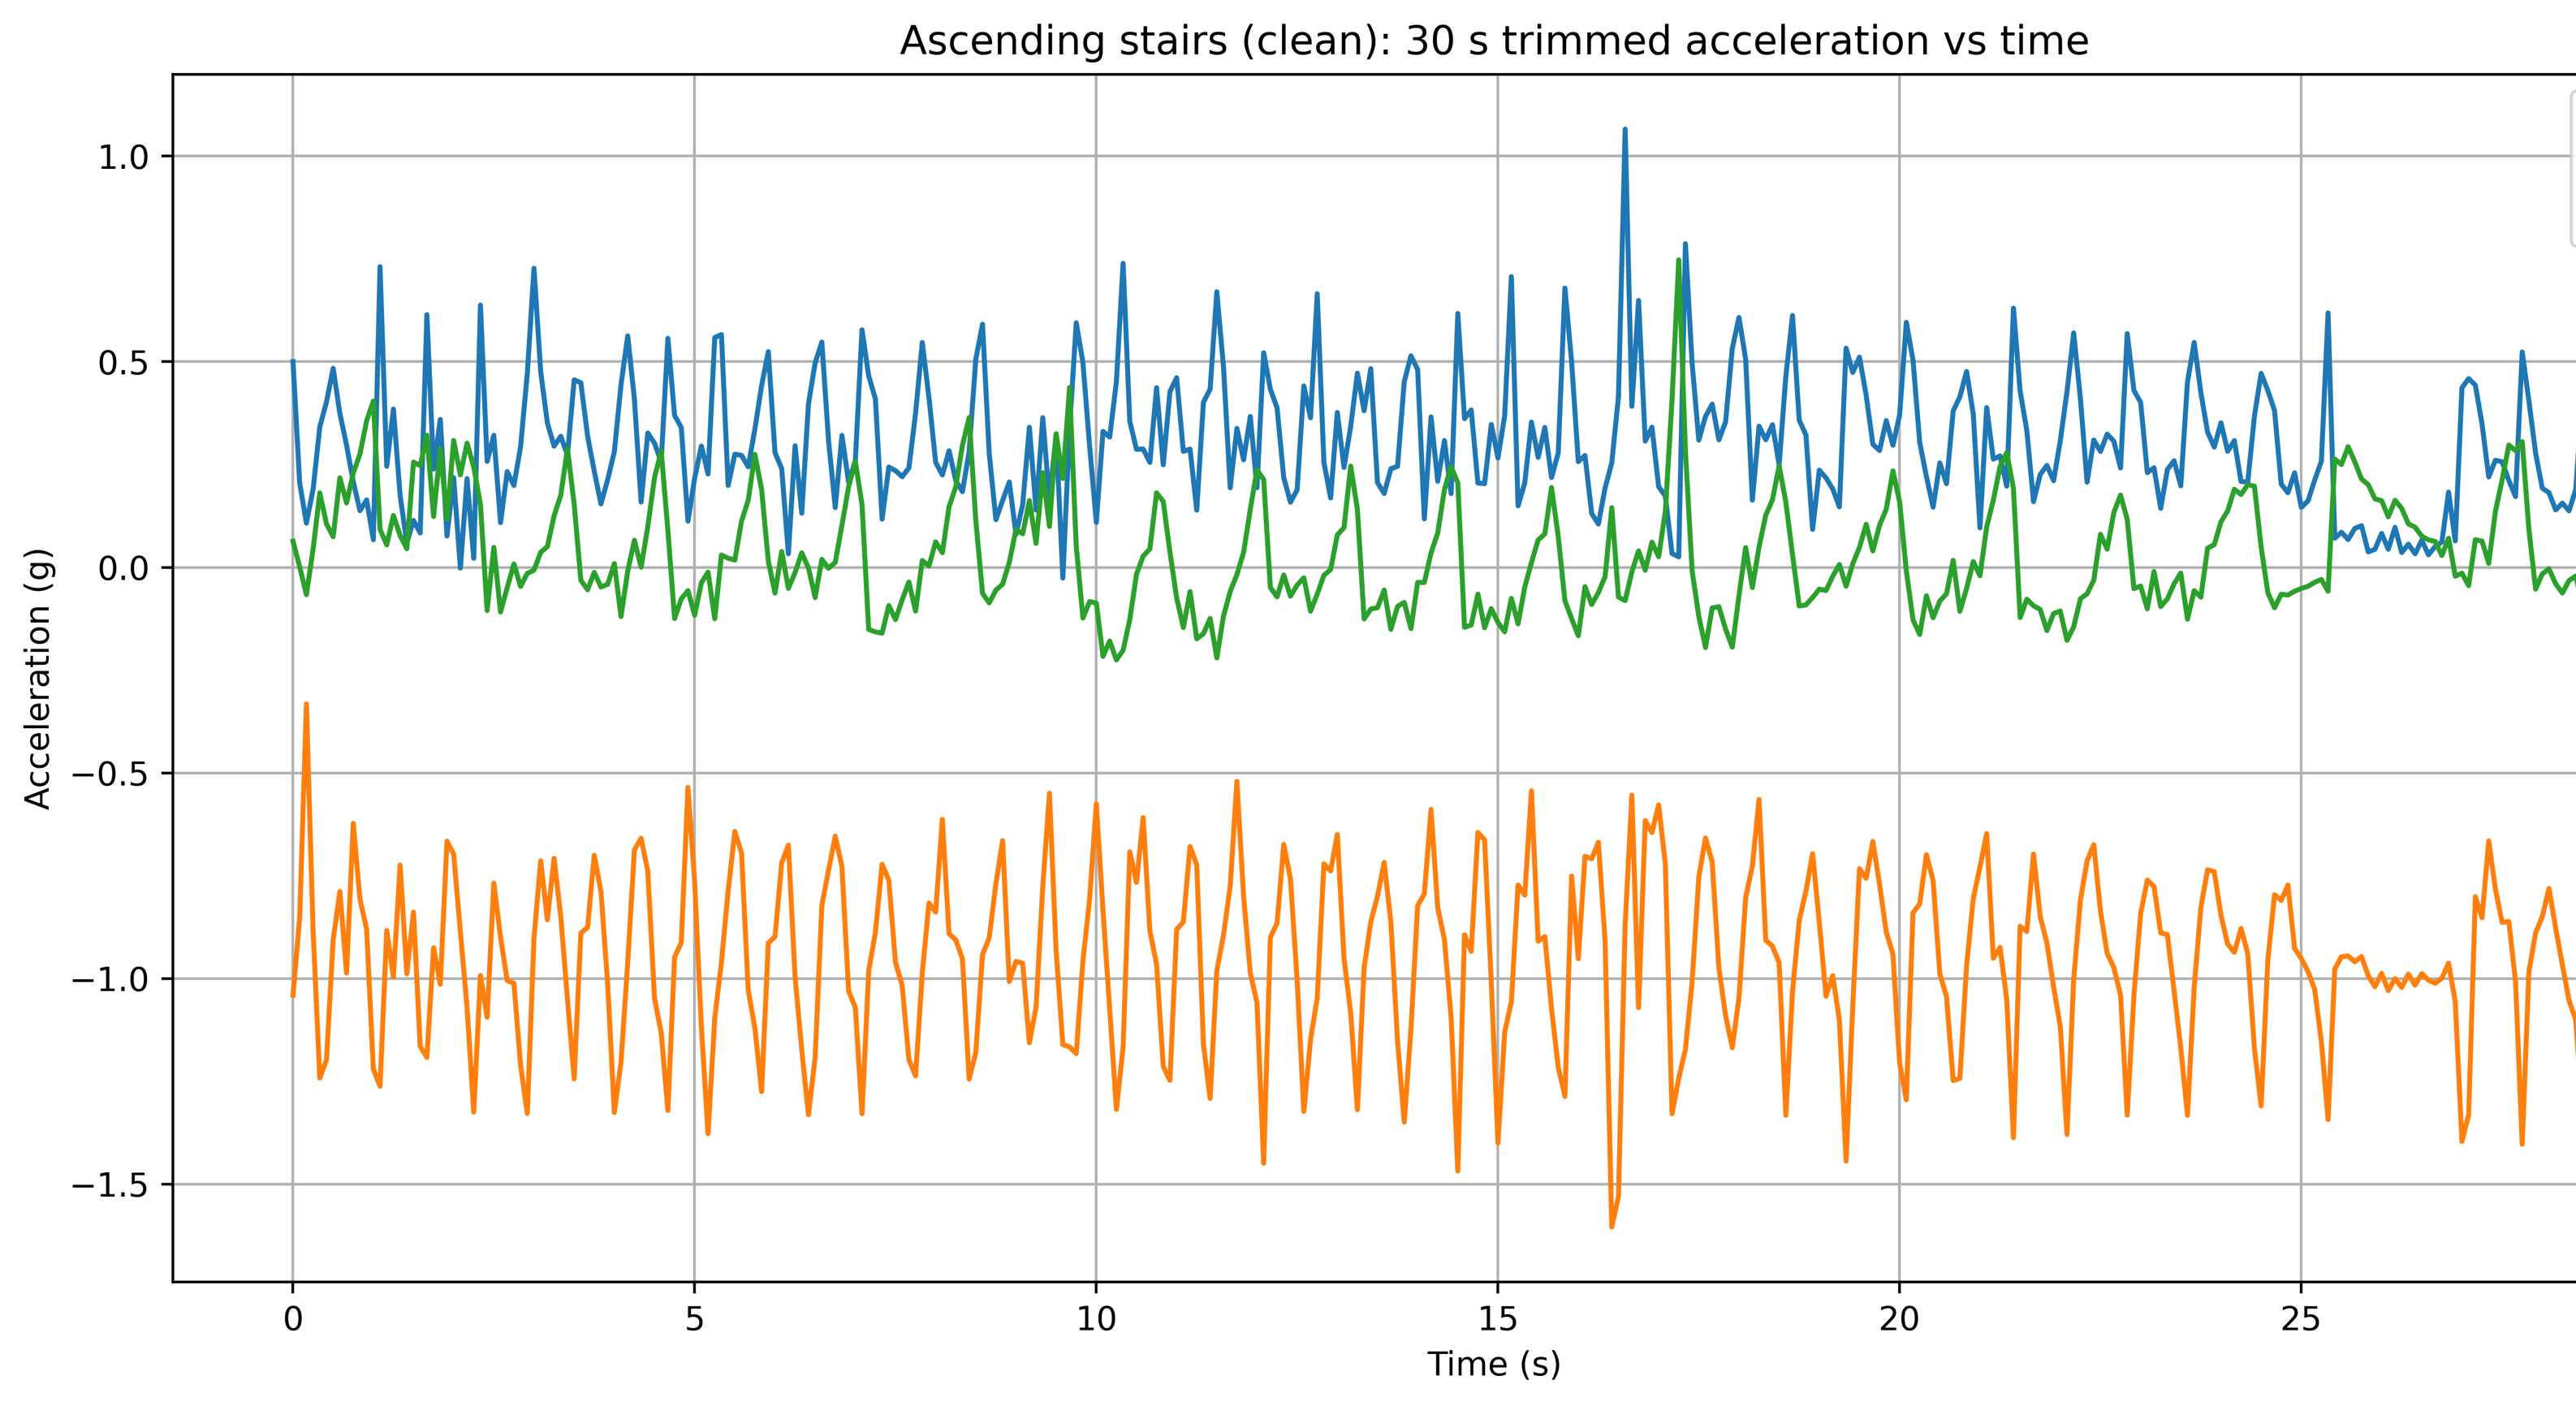
12 Hz chest-worn accelerometer. Two-stage hierarchical classifier (Stage-1 coarse: 4 groups; Stage-2 fine: 12+ activities). Handcrafted time/frequency features, Random Forest · XGBoost · SVM ensemble for clinical activity monitoring.

🚗
Intelligence

Autonomous Car Vision System

Raspberry Pi 4 + PiCamera2. Three sign-detection backends (template matching → custom CNN → YOLOv5), lane following via binary threshold + centroid, UDP JPEG stream.

🤖
Intelligence

Autonomous Differential-Drive Robot

Built from scratch at age 15. Dead-reckoning odometry, 8-sensor ring, 10×10 occupancy grid, Dijkstra planning, boustrophedon coverage. Arduino Mega 2560.

Professional Experience

2024 – 2025
Independent Electronics Contractor
Self-employed — Remote & On-site (Embedded systems · Hardware design · Higher compensation than prior employment)

Operated independently on a project-by-project basis after leaving full-time employment, commanding higher rates than the preceding salaried role. Delivered the STM32H FreeRTOS datalogger system (5 field-iterated versions) under a paid contract, taking sole ownership of firmware architecture, hardware bring-up, and field debugging. Took on additional embedded and hardware design engagements where technical depth and autonomy were the primary requirements.

STM32H743FreeRTOSC Contract / FreelanceEmbedded Systems Hardware Design
2022 – 2024
Electronics R&D Engineer
Sepidgaman Parseh — Tehran & Shiraz, Iran (Biomedical devices · Project contracts)

Worked in an ISO Class 7 cleanroom environment on microbolometer FPA and ROIC inspection systems for thermal imaging. Designed and debugged analog front-ends and mixed-signal PCBs for biomedical instrumentation using Altium Designer. Developed firmware for STM32, AVR, and PIC microcontrollers under production constraints. Wrote Python and MATLAB automation tools for measurement data acquisition and post-processing. Worked closely with Cadence OrCAD/PSpice for circuit simulation. Engagement was primarily through project-based contracts across both the Tehran and Shiraz offices.

STM32AVRAltium Mixed-SignalISO Class 7 Cleanroom Cadence OrCADPythonMATLAB

Robotics Team

A different kind of engineering — not for a client, not for a grade.

Chista Robotics Team

Hardware & Embedded Programmer  ·  2014 – present  ·  Shiraz, Iran

Chista is a serious competitive robotics team based in Shiraz. I joined in 2014 and have been the hardware and embedded programmer since — responsible for microcontroller firmware, sensor integration, motor drivers, and real-time control systems on competition robots. The team competes at a high level in regional and international leagues, but none of us are paid. It is shared passion: the kind of work where you stay up until 3 a.m. before a competition not because you have to, but because you cannot leave a problem unsolved.

Two projects in this portfolio grew directly out of Chista work: the Autonomous Differential-Drive Robot — built from scratch when I was around 15 — and the Autonomous Car Vision System, which applied the same embedded-plus-perception approach to a track-following vehicle. The competition history below spans a decade of that work.

Certificates of participation and awards (where applicable) are available on request.

Competition History

Competition Year
Autonomous Vehicles Tehran 2025
Asia Pacific Robot Contest 2018
Iran Open Robocup 2016, 2017
AUT Cup (Amirkabir University) 2017
FIRA Cup multiple
Shiraz Open 2015

Additional regional competitions not listed. Documentation available on request.

Tools & Skills

Simulation & EDA
COMSOL Multiphysics Lumerical (Python API) Cadence OrCAD / PSpice Cadence Virtuoso (GPDK) Altium Designer MATLAB
Embedded & RTOS
STM32CubeIDE FreeRTOS AVR-GCC Arduino C++ I²C / SPI / UART / RS232
Software & ML
Python PyTorch scikit-learn NumPy / SciPy C / C++ JavaScript
Measurement & Debug
Oscilloscope Spectrum Analyser Wireshark VNA FTIR